Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
ToolDrives GmbH & Co. KG
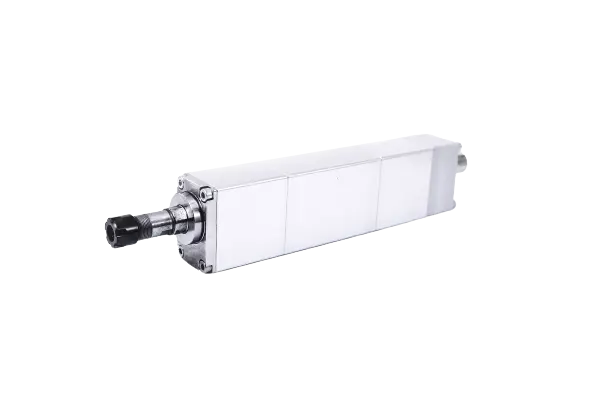
1 kg spindle module for collaborative robots and compact automation systems. Performs drilling, milling, deburring, grinding, and polishing on wood, plastics, and composites with ER11 collet and Weldon tool holders. Slim profile fits space-constrained cells; rated to 40°C ambient.
The ToolDrives Power Drives System BM-PDS is a lightweight cobot spindle module designed for precise machining and drilling tasks in collaborative robot and welding cell applications.
Engineered by ToolDrives, the BM-PDS robot spindle delivers consistent performance in wood, plastics, and composite material processing. Its compact form enables easy integration into automation cells with limited space, enhancing dynamic response for collaborative robots (cobots), gantries, or compact robotics. Mounting interfaces are compatible with common automation platforms, and the spindle works with many cobot models, including those from Yaskawa.
The BM-PDS cobot spindle supports a wide range of tasks, such as drilling, milling, deburring, grinding, and polishing. Ideal use cases include automated drilling stations, robot-mounted finishing, edge processing, and multi-purpose machining of small parts. ToolDrives offers the Power Drives System BM-PDS for prototyping as well as industrial-scale modular machining.
ToolDrives supplies the BM-PDS robot spindle to manufacturers and integrators worldwide. Testimonials from industrial users highlight its reliability and integration simplicity for custom automation projects. Safety and compliance certifications are available upon request from ToolDrives.
The BM-PDS is a lightweight machining spindle designed for small collaborative robots and welding cells, rather than the heavier, space-intensive spindle drives used in standalone CNC or large industrial systems. Choose this spindle when you need precision drilling and finishing on a robot arm where payload and mounting space are tight constraints.